Capture, configure, and command the payload through open aircraft workflows.
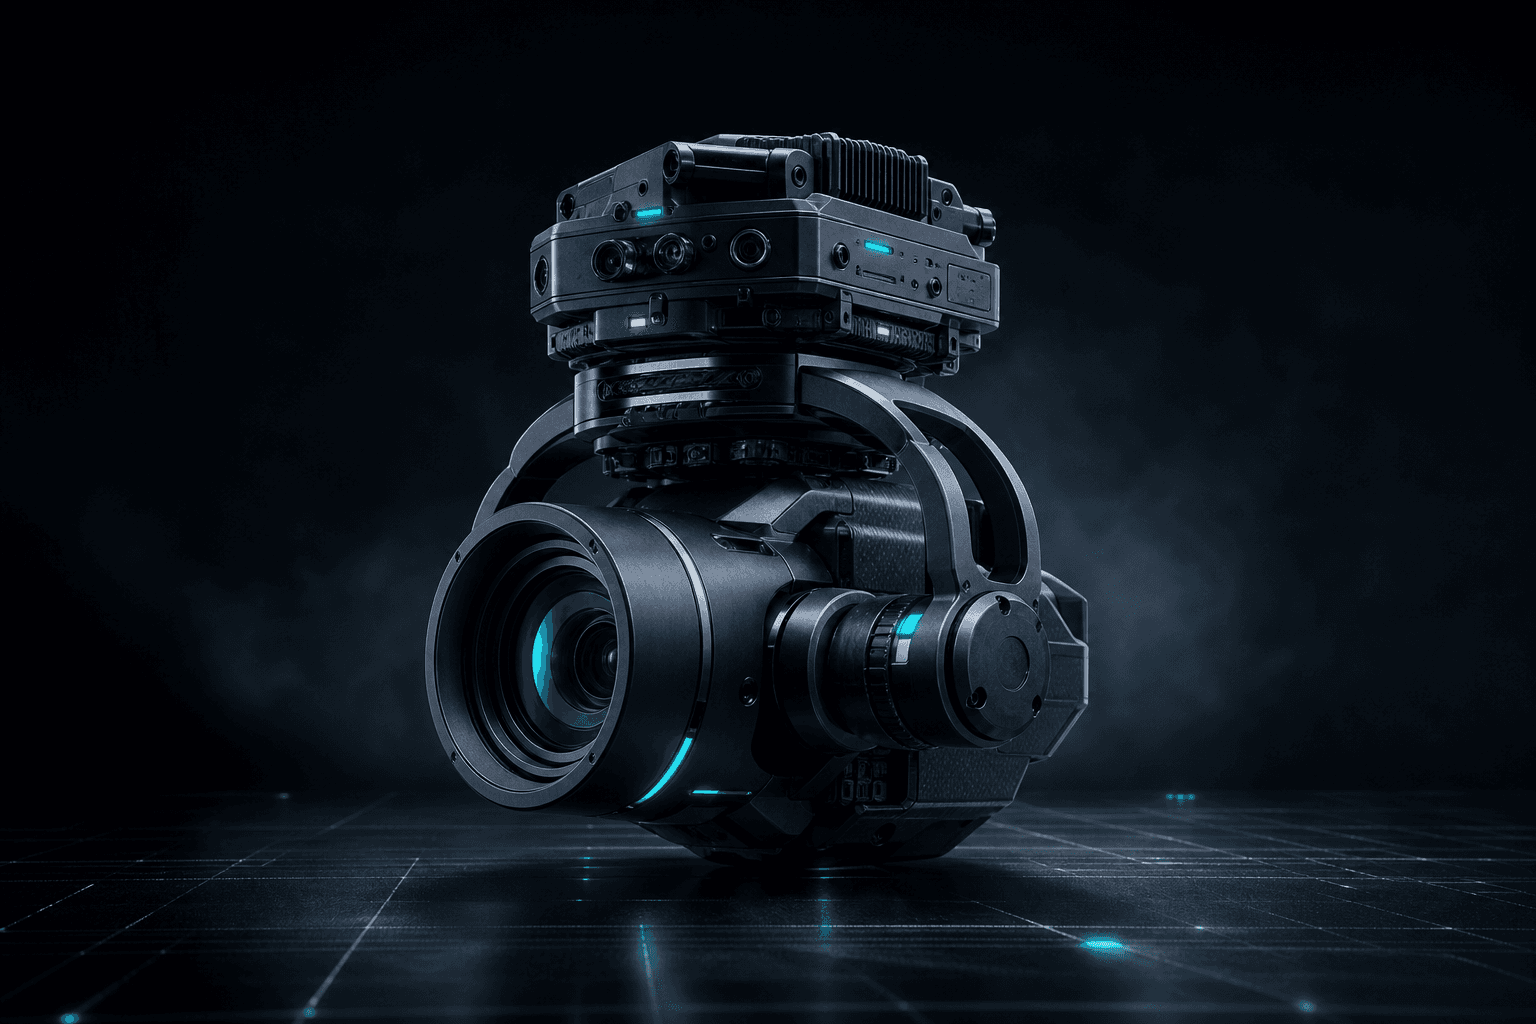
Fokus modular camera & gimbal system
High-resolution aerial imaging for open drone ecosystems.
A camera payload for usable pixels, synchronized metadata, autopilot-native control, and rugged integration.
Scroll to reveal
Why Fokus exists
High-resolution capture, open control, usable metadata.
Fokus gives drone programs a camera payload that captures sharp imagery, talks to the autopilot, and preserves the data behind each frame.
High-resolution imagery with the metadata needed for mapping and inspection.
NDAA-aligned architecture for teams modernizing capable aircraft.
What it is
A modular camera payload built around usable data.
Fokus brings optics, onboard processing, stabilization, storage, and interfaces into one ready-to-install payload.
OpticsSensor and imaging payload
GimbalPan / tilt stabilization core
ControlCompanion and transport boundary
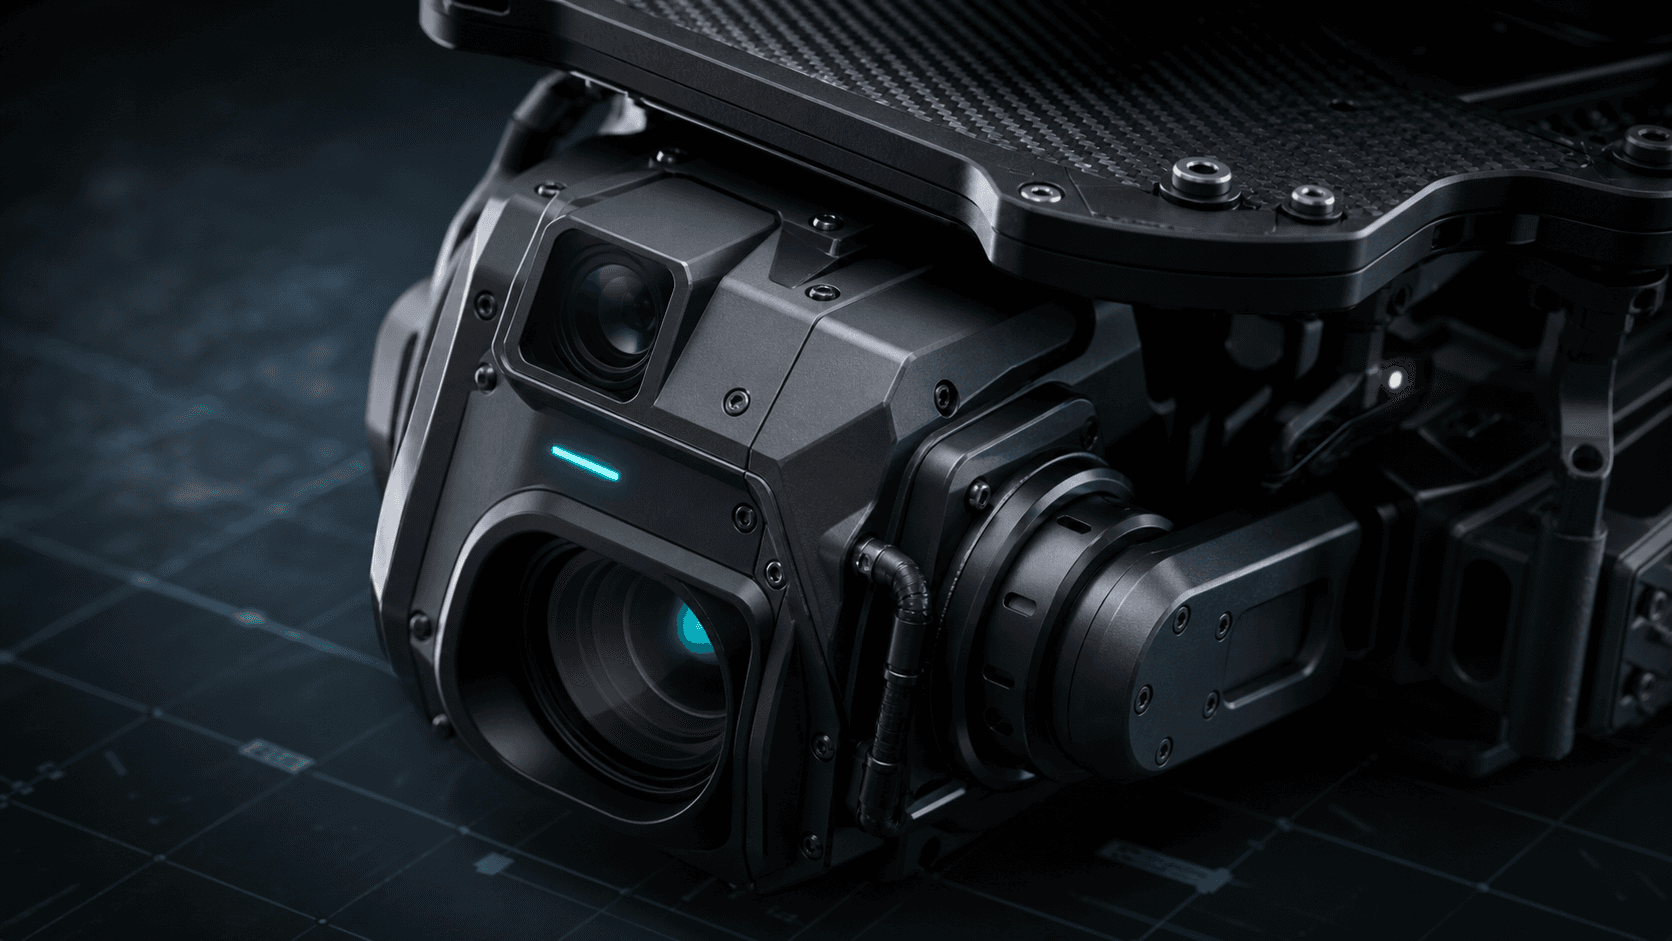
Built for data collection
The image and its context stay together.
Fokus records the camera state, aircraft state, and timing data that make imagery useful after the flight.
01
Raw and usable pixels over cosmetic camera claims
02
GPS, altitude, orientation, timestamp, camera, and lens metadata
03
Exposure-aware timing where achievable
04
Live overlays for aircraft and payload state
05
Capture context ready for downstream processing
PAN 018.4 / TILT -03.1
Precision stabilization
Pan and tilt control that feels mechanical, not abstract.
Smooth actuation keeps the line of sight stable while the aircraft changes attitude. Orientation, command, and response stay visible so operators can trust what the payload is doing in motion.
Imaging story
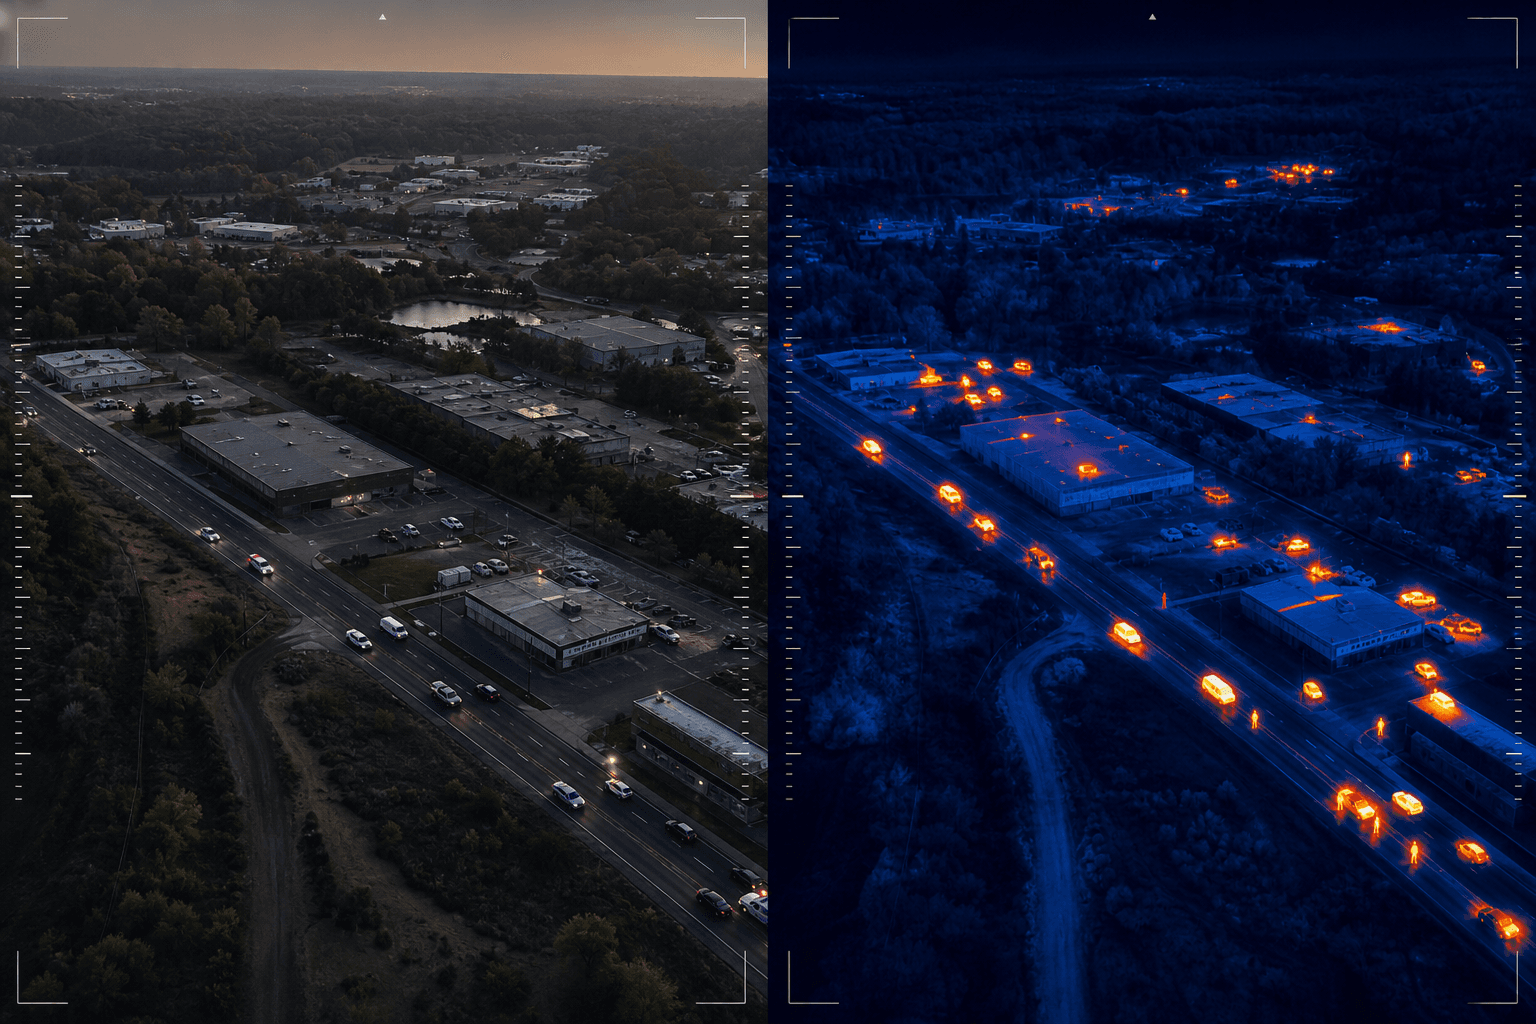
RGB today, multi-sensor architecture tomorrow.
The v1 payload centers on high-resolution RGB stills and 4K video. Thermal, stereo, and other multi-sensor configurations are roadmap extensions, shown here as the direction of the platform.
Core v1 direction
The v1 payload stays focused.
RGB imaging, stabilized control, onboard processing, MAVLink communication, and metadata-aware capture.
Control architecture
Camera, gimbal, aircraft, and compute stay in sync.
MAVLink camera commands, gimbal-manager workflows, telemetry, and transport boundaries stay tied to capture state.
UAV
Flight controller
Companion computer
Redis coordination
Gimbal manager
Camera payload
MAVLink integration
Transport / control separation
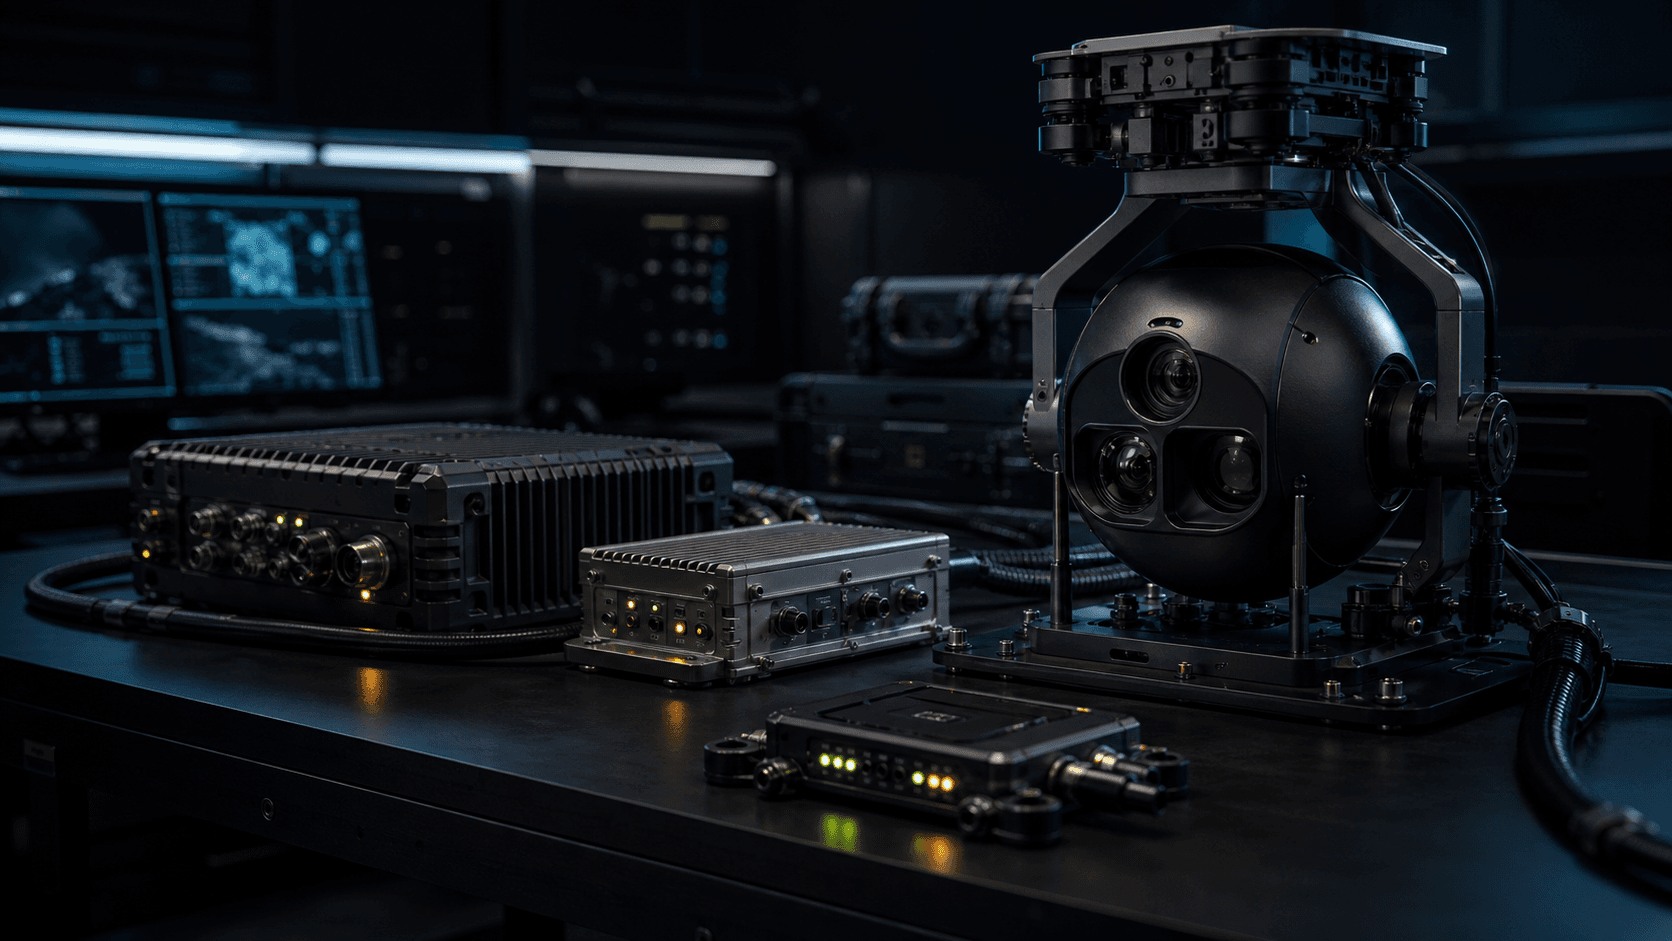
Open integration
Designed for ArduPilot, PX4, and open aircraft programs.
A documented payload module with clear control, data, and mounting boundaries.
Drone-agnostic payload module
Ethernet, UART, SBUS, and IP-based interfaces
Autopilot-native camera and gimbal commands
MAVLink gimbal-manager and ROI workflows
Documented electrical, mechanical, and software boundaries
No bundled airframe or flight controller dependency
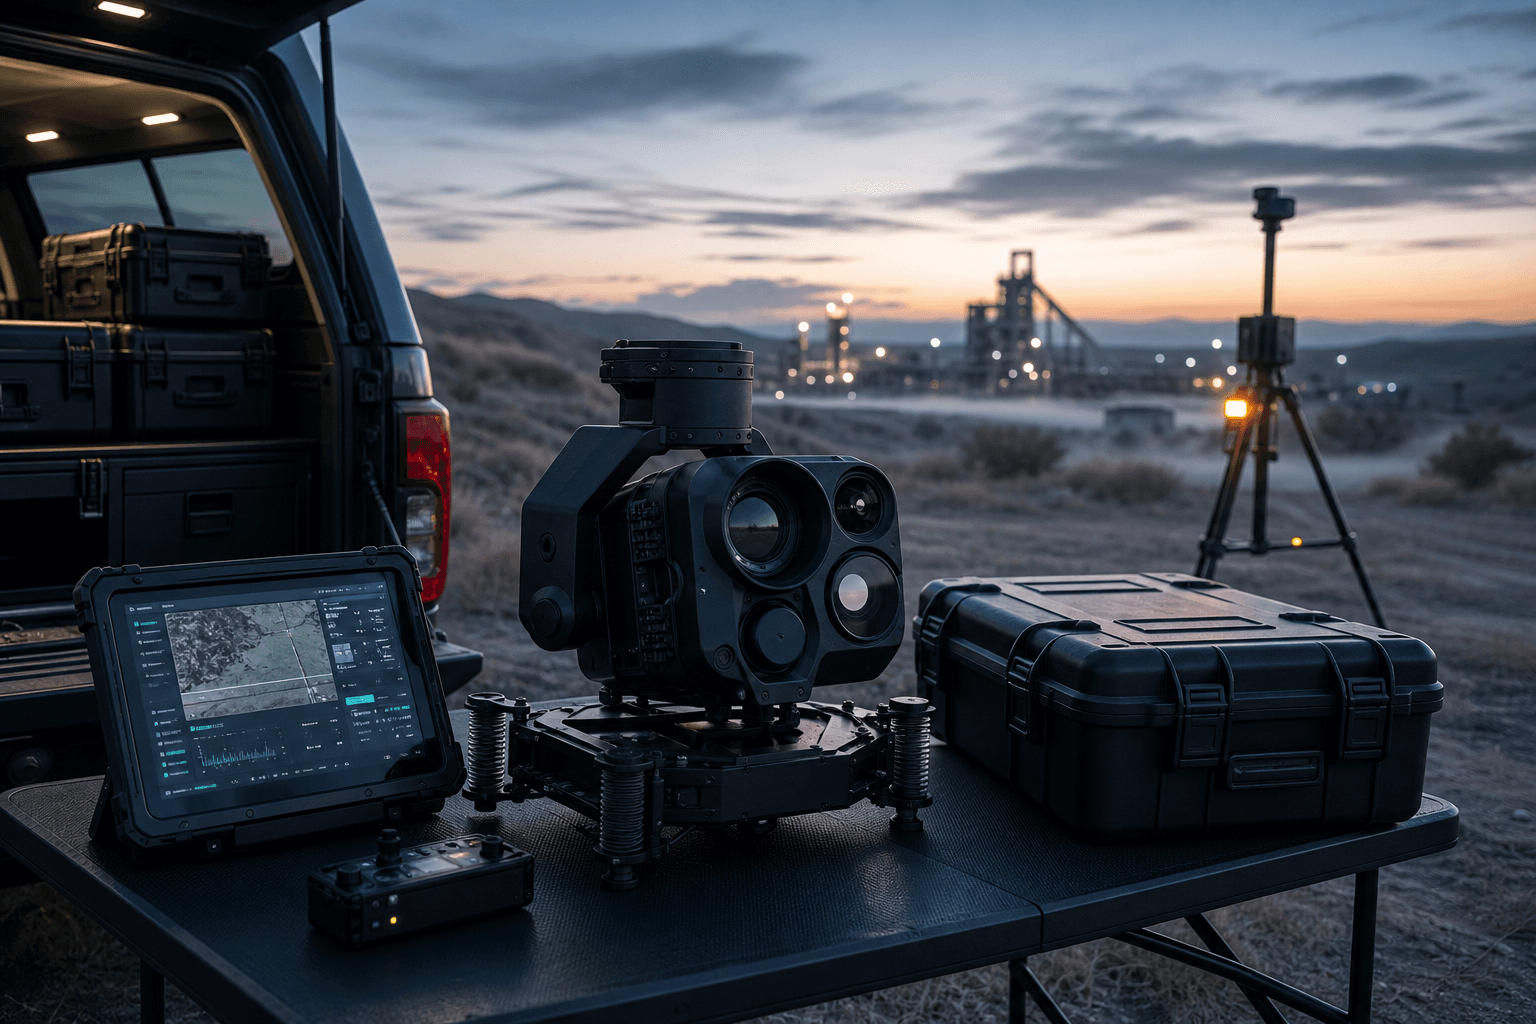
Mission readiness
Built for programs that need credible payload integration.
Fokus is intended for government agencies, public safety teams, infrastructure operators, utilities, research institutions, drone manufacturers, and operators modernizing existing aircraft.
Government
Public safety
Utilities
Infrastructure
Research
OEM programs
Legacy airframes
Mapping
NDAA-aligned roadmap
Traceable by design.
The architecture prioritizes supply-chain traceability, modular component substitution, and documented country-of-origin status. Prototype builds may use commercial parts while production sourcing is validated.
Roadmap capability
Roadmap stays separate from v1.
RGB is the v1 baseline. Thermal, stereo, AI, multi-sensor, and FPGA paths are expansion tracks.
Verification mindset
Tested in layers, from bench to flight.
Operational imagery
Additional views for the launch story.
Materials
Machined surfaces, sealed ports, precision fastening.
Integration
Companion-computer workflows, staged before the airframe.
Deployment
Operational staging for inspection, public safety, and autonomy.
Feature highlights
The payload layer for advanced aerial robotics.
Single-sensor v1 direction with >=24MP still capture
4K video capability with HDMI and/or IP-based output paths
Integrated 3-axis pan, tilt, and roll control
MAVLink-native workflows for ArduPilot and PX4 ecosystems
GPS, orientation, timestamp, altitude, and camera identity association
Jetson-class processing for capture, encoding, and coordination
USB 3.0 camera path with Ethernet, UART, SBUS, and IP integration options
Fokus pilot programs
Bring the payload into your next airframe conversation.
Schedule a technical walkthrough for demos, integration planning, and payload evaluation.